Quantitative imaging at base temperature
Capacitive feedback ties image pixels to real distances rather than to applied voltage.
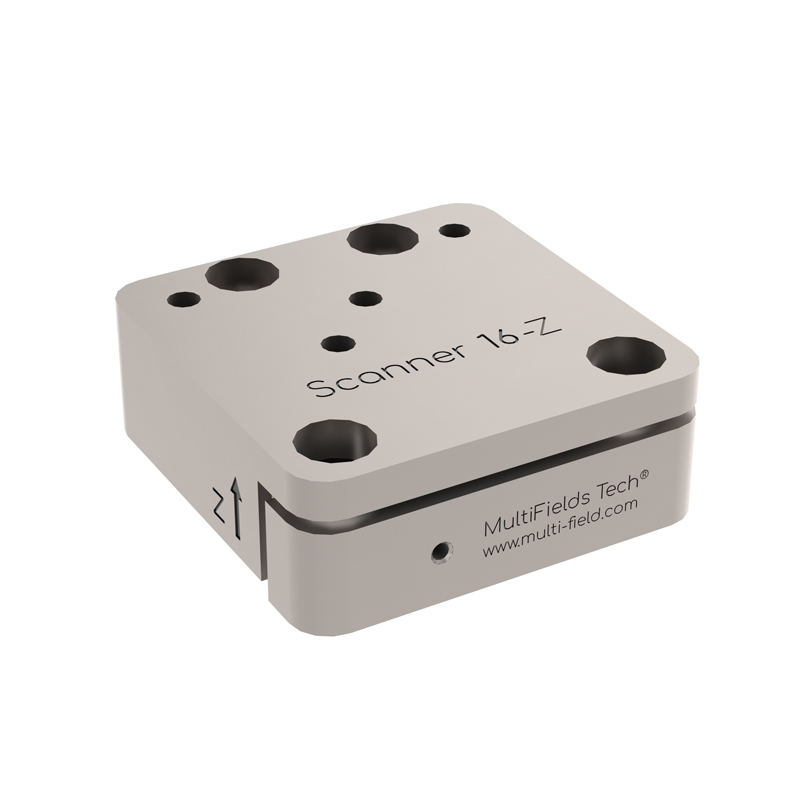
Opto-Mechanics · Cryogenic Piezo Stages - Closed-loop Ultra scanners
Closed-loop Ultra Z-axis scanner; 25 x 25 x 10.5 mm body; 55 um range per axis at 300 K, 30 um at 4 K; 250 g payload; integrated capacitive displacement sensor, 0.5 nm resolution, ~0.1 % linearity, <5 nm repeatability; max. 75 V @300 K / 150 V @4 K; combined UHV plus ultra-low-temperature grade down to 30 mK; use with MC-ArchimedesLT.03.Ultra controller.
Datasheet (PDF) ↗CAD Model (STEP) ↗Catalog context
Scanner25-z.Ultra.UHV.ULT is listed in the Cryogenic Piezo Stages - Closed-loop Ultra scanners family. The local catalog record provides these first selection fields: Active axes: Z; Footprint × hight: 25 x 25 x 10.5 mm; Mass: 80 g.
| Active axes | Z |
|---|---|
| Footprint × hight | 25 x 25 x 10.5 mm |
| Mass | 80 g |
| Work Environment | Default: 1.4 K~ 400 K, 1e-7 mbar, 35 Tesla |
| Option 1 - 30 mK | .ULT / .UHV.ULT |
| Option 2 - 2e-11 mbar | .UHV / .UHV.ULT |
| Mainbody | Default: Pure Ti, ULT: BeCu |
| Wires | Twisted paired wire & triax cable |
| Connectors | 2 head pins + 1 triax connector (for each dimension) |
| Travel range | @300 K: 55 um; @4 K: 30 um |
| Drive Voltage | Max. 75 V @300 K, Max. 150 V @4 K |
| Max. Load | 250 g |
| Capacitance @300 K | 7 uF |
| Sensor | Capacitive displacement sensor |
| Resolution | 0.5 nm |
| Linearity error | Typical ~0.1 % |
| Repeatibility | <5 nm |
Application context
Capacitive feedback ties image pixels to real distances rather than to applied voltage.
Deliver linear, drift-corrected scan under a probe head operating below 4 K.
Return to the same coordinate across thermal cycles and long measurement campaigns.
System integration
Use these checks to connect Scanner25-z.Ultra.UHV.ULT to the surrounding optical, mechanical and control system. Every value shown is taken from this model's own specification record.
Technical FAQ
Travel range: @300 K: 55 um; @4 K: 30 um · Resolution: 0.5 nm. Separate travel from resolution and both from repeatability. Repeatability is what an automated sequence actually depends on, and it is the figure most often absent from a headline specification.
Sensor: Capacitive displacement sensor. Pair open-loop mechanics with the specified high-voltage or inertial driver, and closed-loop variants with the controller their capacitive, strain-gauge or encoder feedback requires. Matching connectors do not guarantee electrical compatibility.
Max. Load: 250 g. Check the load rating in the orientation you will use it — a vertical or cantilevered load is a moment, not a mass — and match the base to an M6 pattern on a 25 mm grid or a 1/4"-20 pattern on a 1 inch grid.
Option 1 - 30 mK: .ULT / .UHV.ULT. Use only the environmental suffix listed for the ordered configuration, and treat cabling, lubricant, bakeout and thermal anchoring as part of the same specification.
Specifying this part
An integrated capacitive displacement sensor closes the loop at 0.5 nm and lets the controller compensate thermal drift, piezoelectric creep and self-heating actively. Worth the extra wiring only if the measurement holds position for hours; if the sample is re-found optically each run, open-loop costs less heat.
The suffix sets the environmental preparation, not the mechanics: HV, UHV, ULT and UHV.ULT variants differ in materials, cabling and bake compatibility. Match it to the chamber the stage will live in — the mechanical specification is identical across them.
Stick-slip inertial drives dissipate energy per step and draw no holding current once stopped, so the steady-state load on the mixing chamber is the wiring loom rather than the motor. Anchor the loom at each temperature stage and thermalise the moving body with an FTC copper braid.
Titanium bodies (BeCu on the .ULT variants) and BeCu fasteners throughout, rated for operation to 35 T and down to 30 mK with the .ULT option, at 2 × 10⁻¹¹ mbar with .UHV. A single steel screw substituted at installation is enough to compromise a high-field assembly.
Full series comparison, controller pairing and mounting hardware on the cryogenic piezo stages overview, or work through the selection with the configurator.
Model selection
Compare Scanner25-z.Ultra.UHV.ULT with the closest available models in the Cryogenic Piezo Stages - Closed-loop Ultra scanners family.
| Selection parameter | Scanner25-z.Ultra.UHV.ULT (current) | Scanner25-z.Ultra.UHV | Scanner25-z.Ultra.ULT |
|---|---|---|---|
| Travel / adjustment | @300 K: 55 um; @4 K: 30 um | @300 K: 55 um; @4 K: 30 um | @300 K: 55 um; @4 K: 30 um |
| Resolution / sensitivity | 0.5 nm | 0.5 nm | 0.5 nm |
Scanner25-x.Ultra
Closed-loop Ultra X-axis scanner; 25 x 25 x 10.5 mm body; 55 um range per axis at 300 K, 30 um at 4 K; 250 g payload; integrated capacitive displacement sensor, 0.5 nm resolution, ~0.1 % linearity, <5 nm repeatability; max. 75 V @300 K / 150 V @4 K; standard cryogenic environment grade; use with MC-ArchimedesLT.03.Ultra controller.
Scanner25-x.Ultra.HV
Closed-loop Ultra X-axis scanner; 25 x 25 x 10.5 mm body; 55 um range per axis at 300 K, 30 um at 4 K; 250 g payload; integrated capacitive displacement sensor, 0.5 nm resolution, ~0.1 % linearity, <5 nm repeatability; max. 75 V @300 K / 150 V @4 K; high-vacuum HV environment grade; use with MC-ArchimedesLT.03.Ultra controller.
Scanner25-x.Ultra.UHV
Closed-loop Ultra X-axis scanner; 25 x 25 x 10.5 mm body; 55 um range per axis at 300 K, 30 um at 4 K; 250 g payload; integrated capacitive displacement sensor, 0.5 nm resolution, ~0.1 % linearity, <5 nm repeatability; max. 75 V @300 K / 150 V @4 K; ultra-high-vacuum UHV environment grade; use with MC-ArchimedesLT.03.Ultra controller.
Scanner25-x.Ultra.ULT
Closed-loop Ultra X-axis scanner; 25 x 25 x 10.5 mm body; 55 um range per axis at 300 K, 30 um at 4 K; 250 g payload; integrated capacitive displacement sensor, 0.5 nm resolution, ~0.1 % linearity, <5 nm repeatability; max. 75 V @300 K / 150 V @4 K; ultra-low-temperature ULT grade down to 30 mK; use with MC-ArchimedesLT.03.Ultra controller.
Before you specify
Engineering context for choosing this class of component, with the tradeoffs worked through on real specifications.
 Precision motion
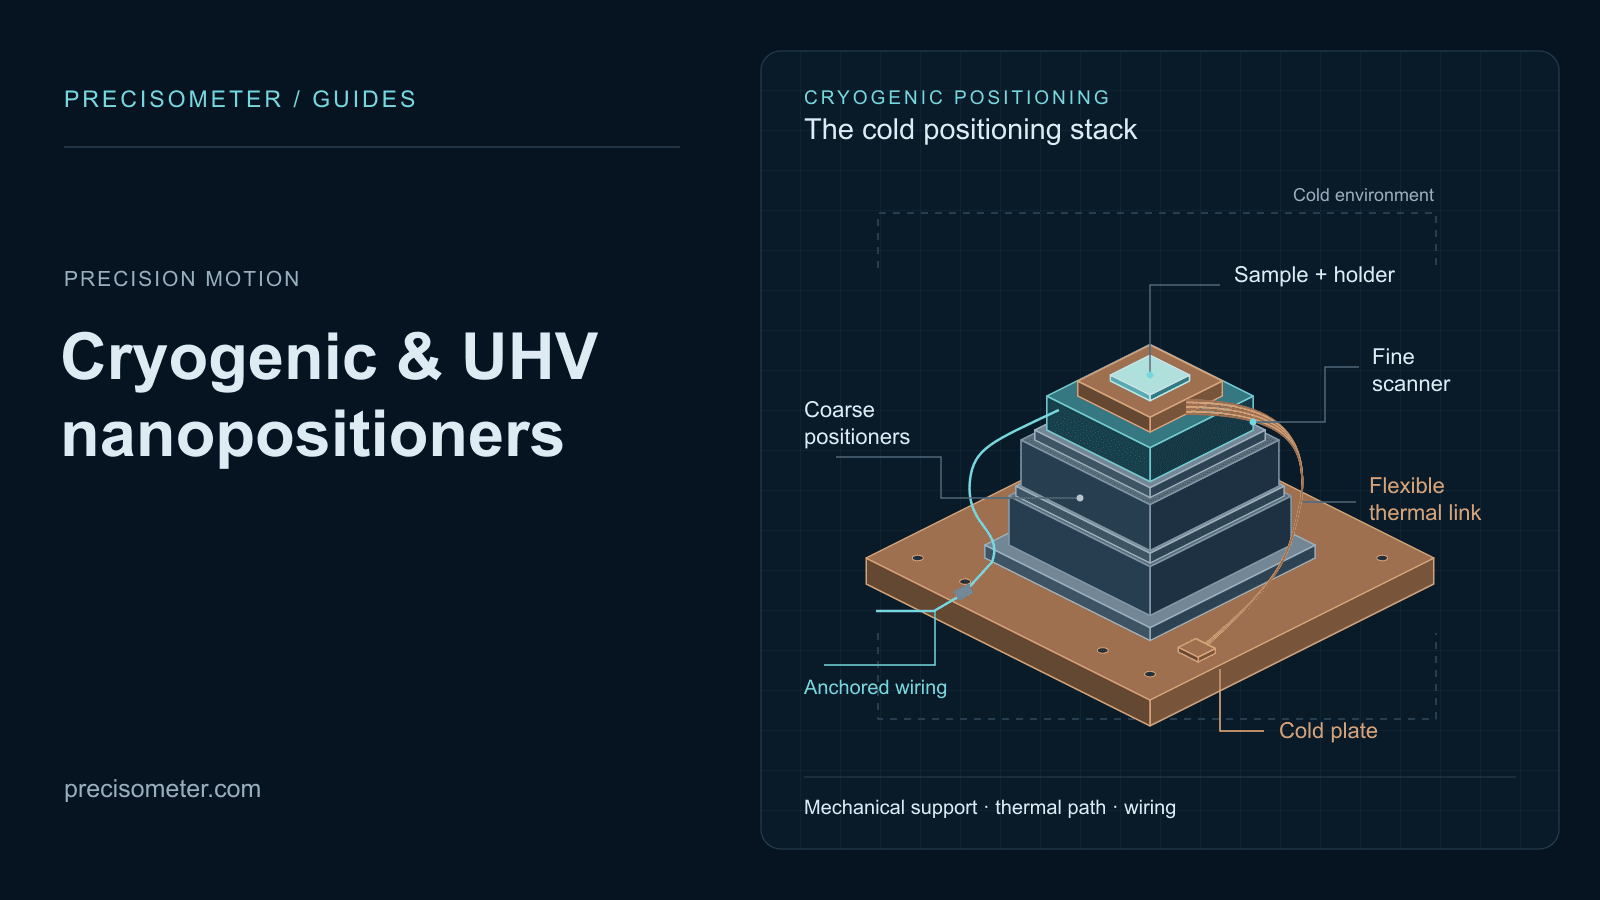
Translate temperature, pressure, travel, payload, feedback, and motion requirements into a defensible cryogenic-stage shortlist.
Open guide Precision motion
The practical companion to the selection guide: a requirements worksheet, coarse and fine stage pairing, mechanical stack order, thermal anchoring, the wiring chain to the controller, vacuum and field checks, a commissioning sequence, and three worked configurations.
Open guide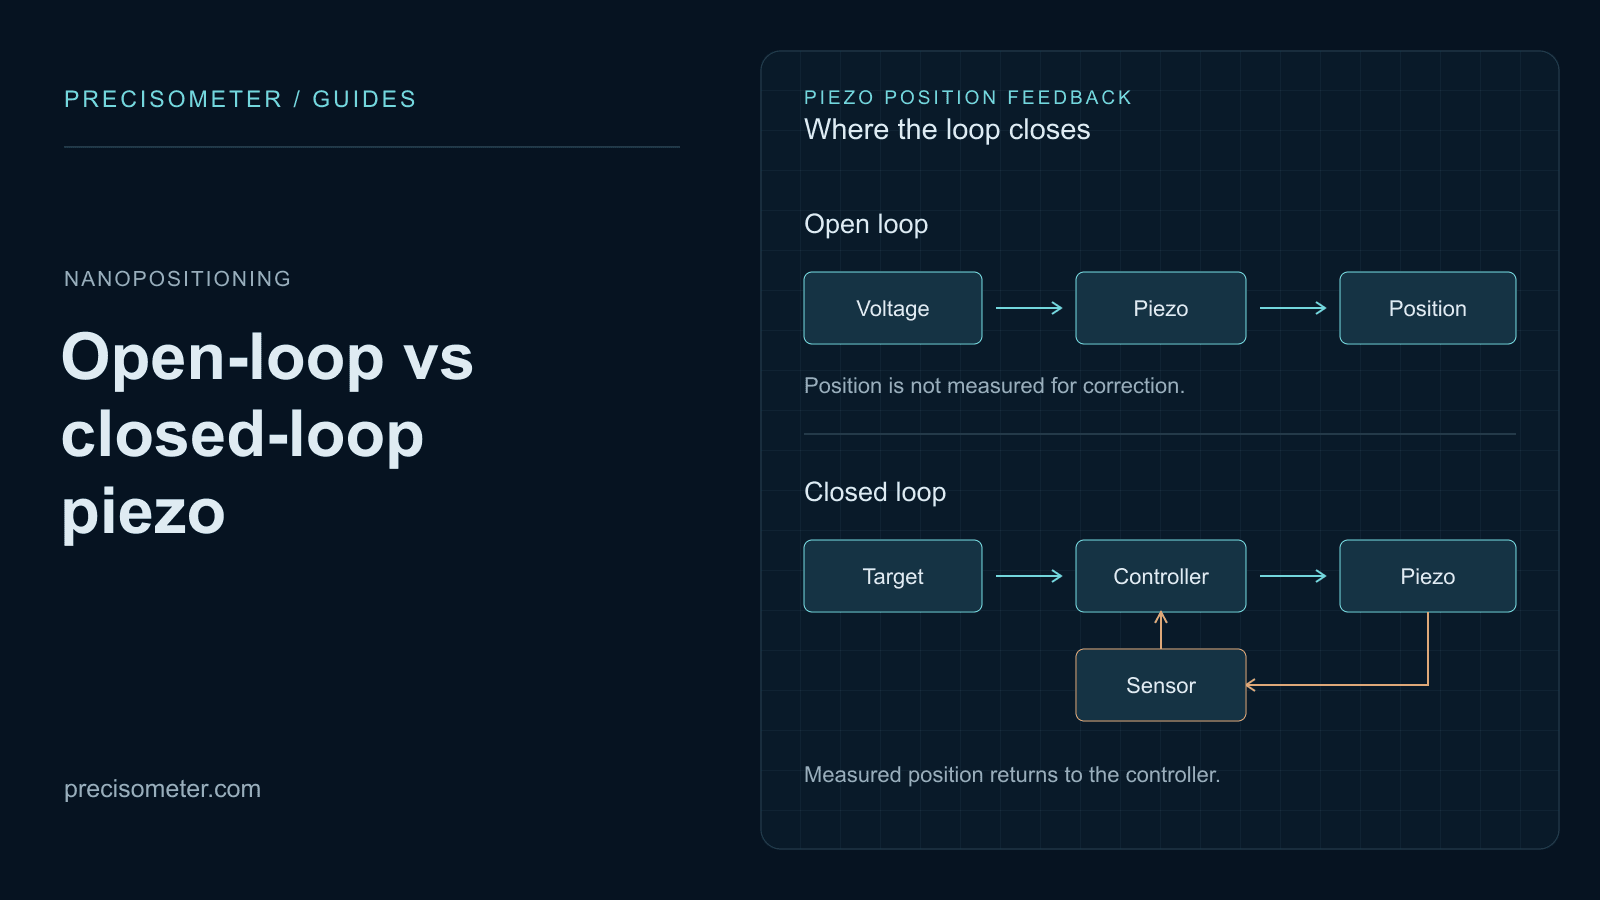 Nanopositioning
Why an open-loop piezo is wrong by 15 % of its travel, how creep grows with the logarithm of hold time, what strain-gauge and capacitive feedback actually fix — and the bandwidth and sensor noise a servo costs you in return.
Open guide