Driving stages through cryostat wiring
Compensate the cable capacitance and attenuation of a long run into a cold environment.
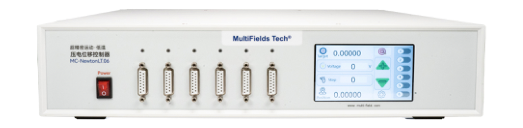
Representative image of the product family.
Opto-Mechanics · Cryogenic Piezo Stages - Controllers
Six-channel cryogenic piezo positioner controller for multi-axis positioner stacks and long-stroke assemblies operating in cryogenic and vacuum chambers. Delivers independent -200 V to +200 V bipolar drive signals at 1–10 kHz with 40 W peak power per channel and dedicated isolated ground paths. Features 6-channel 18-bit resistive encoder feedback, front-panel touchscreen and fine-tuning knobs, USB and TCP/IP Ethernet interfaces, and LabVIEW / SDK support in a 19-inch 3U chassis.
Datasheet (PDF) ↗Catalog context
MC-NewtonLT.06 is listed in the Cryogenic Piezo Stages - Controllers family. The local catalog record provides these first selection fields: Controlled channels: 6 channels (independent cryogenic multi-axis drive); Compatible positioners: MultiFields cryogenic linear, rotator, goniometer & LS-Linear stages; Control mode: All 6 channels independent closed-loop stick-slip driving + fine tuning.
| Controlled channels | 6 channels (independent cryogenic multi-axis drive) |
|---|---|
| Compatible positioners | MultiFields cryogenic linear, rotator, goniometer & LS-Linear stages |
| Control mode | All 6 channels independent closed-loop stick-slip driving + fine tuning |
| Max output voltage | -200 V ~ +200 V |
| Drive frequency range | 1 ~ 10 kHz |
| Output power | Max. 40 W per channel |
| Slew rate | 2 kV/µs |
| Drive output grounding | 6 channels independent isolated GND |
| Compatible encoder | Cryogenic resistive encoder |
| Sensor readout resolution | 50 µV (18-bit ADC) |
| Sensor excitation voltage | 2.5 V DC |
| Sensor input resistance | 10 kΩ |
| Sensor readout grounding | 6 channels independent isolated GND |
| Host communication interface | USB & TCP/IP Ethernet |
| Enclosure form factor | 19-inch rack-mount / 3U |
| Power supply | 220 V AC, 60 W |
| User interface | Front-panel touchscreen display and manual fine-tuning controls |
| Stage connectors | 6 × D-Sub 15 |
Application context
Compensate the cable capacitance and attenuation of a long run into a cold environment.
Read cryogenic position sensors and servo against them where piezo response changes with temperature.
Sequence coarse and fine axes from one controller so an approach routine can run unattended.
System integration
Use these checks to connect MC-NewtonLT.06 to the surrounding optical, mechanical and control system. Every value shown is taken from this model's own specification record.
Technical FAQ
Sensor readout resolution: 50 µV (18-bit ADC). Separate travel from resolution and both from repeatability. Repeatability is what an automated sequence actually depends on, and it is the figure most often absent from a headline specification.
Compatible encoder: Cryogenic resistive encoder. Pair open-loop mechanics with the specified high-voltage or inertial driver, and closed-loop variants with the controller their capacitive, strain-gauge or encoder feedback requires. Matching connectors do not guarantee electrical compatibility.
Specifying this part
MC-NewtonLT drives coarse inertial stages (Linear, Rotator, Goniometer) in 1- and 6-channel versions over USB and TCP/IP. MC-ArchimedesLT drives scanners with sub-millivolt output noise. Only the .03.Ultra closes a capacitive loop, sampling at 50 kSa/s over EtherCAT, EtherNET or USB 3.0.
LabVIEW, C++ and Python APIs are supplied, so the stage can be sequenced from the same script that runs the measurement rather than driven by hand between points.
Stick-slip inertial drives dissipate energy per step and draw no holding current once stopped, so the steady-state load on the mixing chamber is the wiring loom rather than the motor. Anchor the loom at each temperature stage and thermalise the moving body with an FTC copper braid.
Titanium bodies (BeCu on the .ULT variants) and BeCu fasteners throughout, rated for operation to 35 T and down to 30 mK with the .ULT option, at 2 × 10⁻¹¹ mbar with .UHV. A single steel screw substituted at installation is enough to compromise a high-field assembly.
Full series comparison, controller pairing and mounting hardware on the cryogenic piezo stages overview, or work through the selection with the configurator.
Model selection
Compare MC-NewtonLT.06 with the closest available models in the Cryogenic Piezo Stages - Controllers family.
| Selection parameter | MC-NewtonLT.06 (current) | MC-NewtonLT.01 | MC-ArchimedesLT.03.Ultra |
|---|---|---|---|
| Resolution / sensitivity | 50 µV (18-bit ADC) | 50 µV (18-bit ADC) | Sub-nanometer closed-loop resolution |
MC-NewtonLT.01
Single-channel cryogenic piezo positioner controller designed for extreme environments (down to 4 K and UHV). Combines high-voltage coarse stick-slip driving (-200 V to +200 V, 1–10 kHz, 40 W) with fine analog positioning. Equipped with 18-bit (50 µV) resistive encoder readout, independent ground isolation, front-panel touchscreen and fine-tuning knob, USB and TCP/IP Ethernet communication, and full LabVIEW / SDK automation support in a 19-inch 3U rack-mount enclosure.
MC-ArchimedesLT.03
Three-channel open-loop cryogenic scanner controller designed for MultiFields low-temperature flexure scanners (Scanner 16, 25, and 35 series). Features ultra-low-noise high-voltage amplifiers delivering -150 V to +150 V with 3 mV resolution up to 1 kHz frequency. Includes 3 BNC output channels, -10 V to +10 V analog inputs, USB and TCP/IP Ethernet remote control, and a 19-inch 3U rack-mountable enclosure.
MC-ArchimedesLT.03.Ultra
High-speed 3-channel closed-loop cryogenic scanner controller engineered for MultiFields closed-loop Ultra flexure scanning stages. Features 50 kSa/s real-time sampling and master-slave SPI communication for sub-nanometer displacement precision and tunable analog bandwidth. Integrates synchronous capacitive sensor feedback loops, EtherCAT, Ethernet, USB 3.0, BNC/SMA analog I/O, and hardware trigger terminals for synchronized scanning probe and cryogenic imaging systems.
Before you specify
Engineering context for choosing this class of component, with the tradeoffs worked through on real specifications.
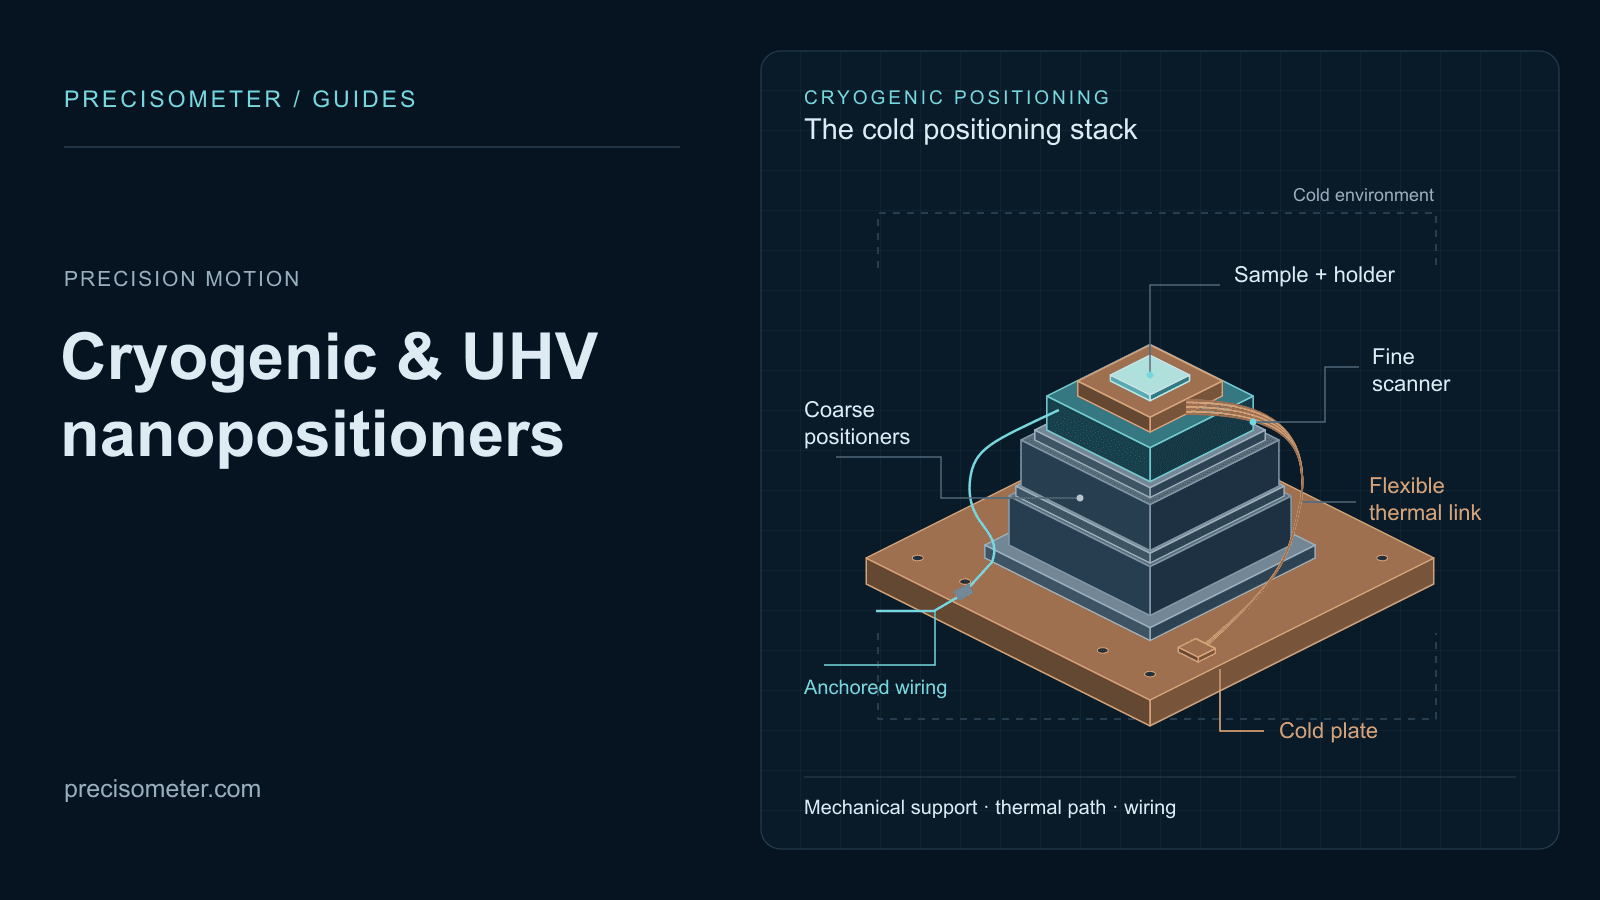 Precision motion
Translate temperature, pressure, travel, payload, feedback, and motion requirements into a defensible cryogenic-stage shortlist.
Open guide Precision motion
The practical companion to the selection guide: a requirements worksheet, coarse and fine stage pairing, mechanical stack order, thermal anchoring, the wiring chain to the controller, vacuum and field checks, a commissioning sequence, and three worked configurations.
Open guide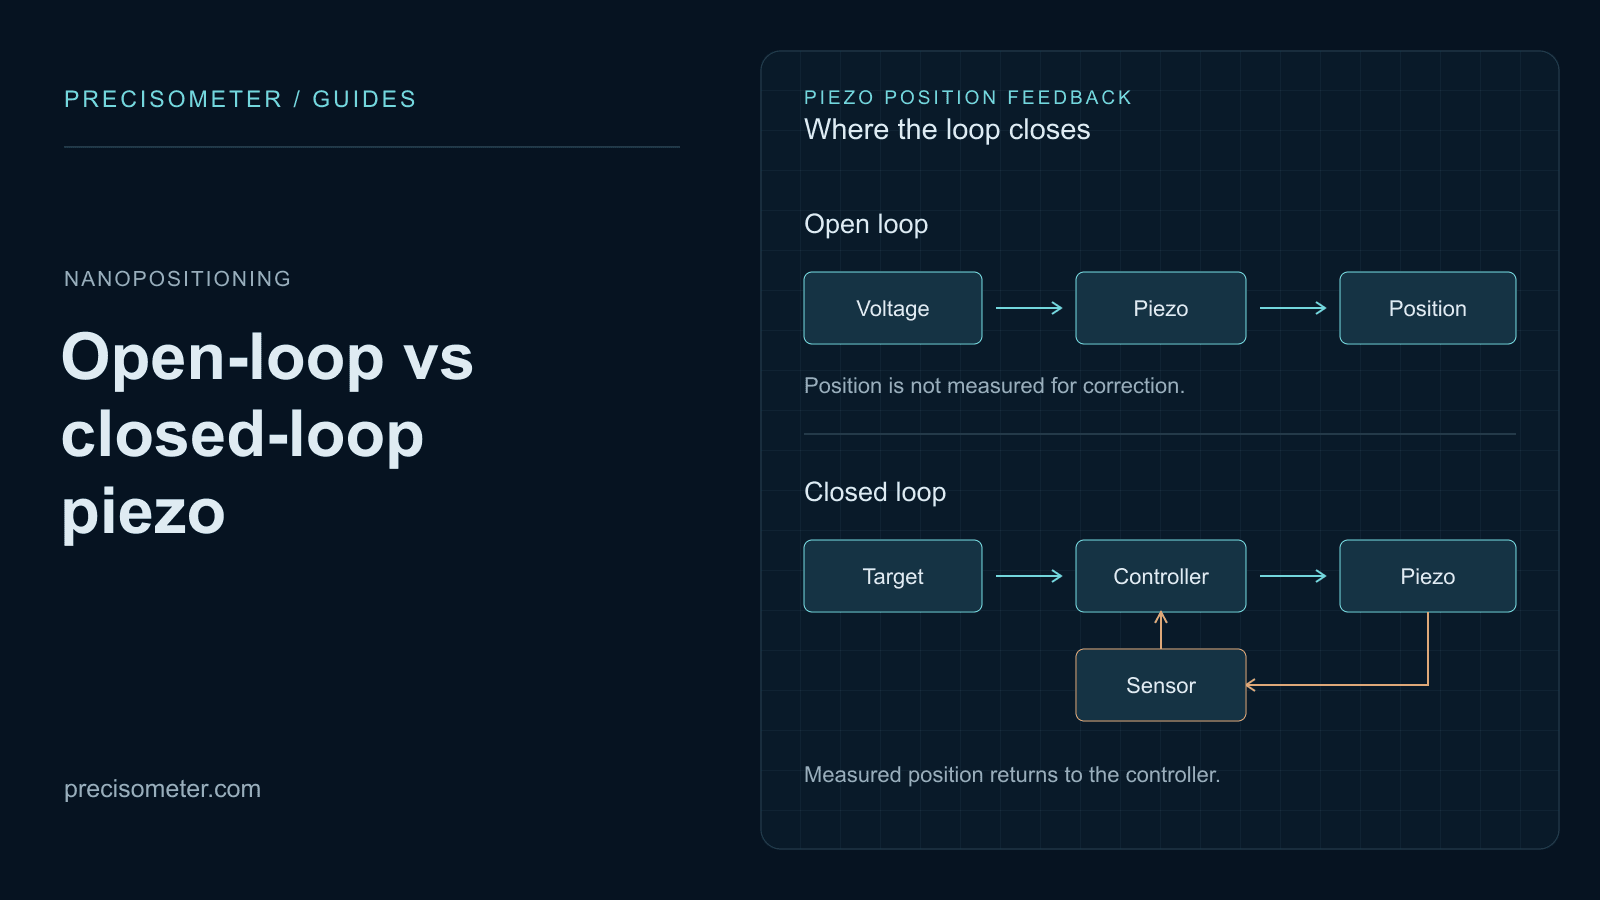 Nanopositioning
Why an open-loop piezo is wrong by 15 % of its travel, how creep grows with the logarithm of hold time, what strain-gauge and capacitive feedback actually fix — and the bandwidth and sensor noise a servo costs you in return.
Open guide