Sample positioning in cryostats
Move a sample under a fixed optical access port at temperatures down to the millikelvin range.
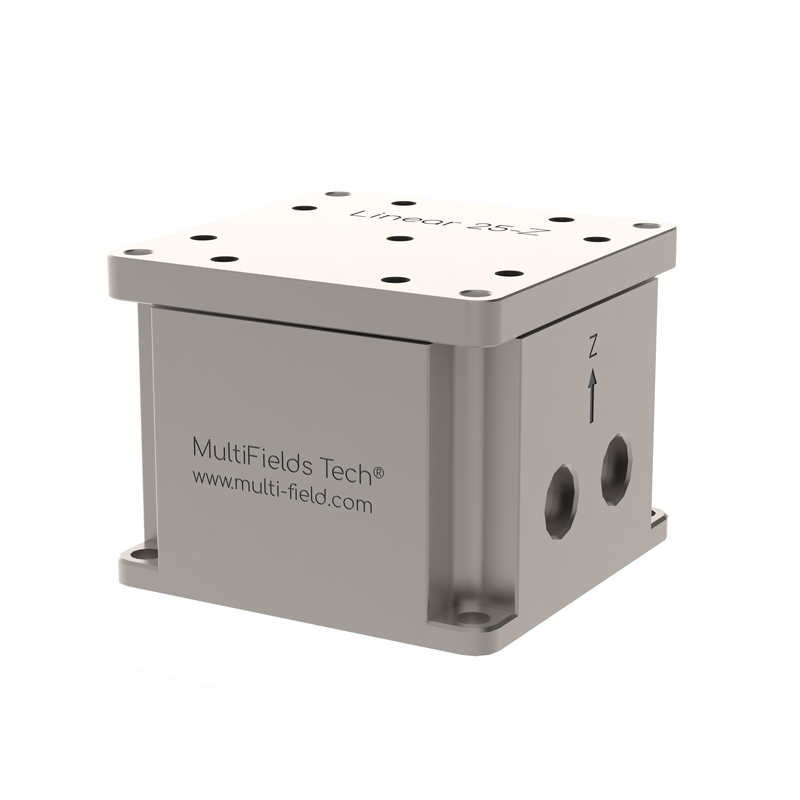
Opto-Mechanics · Cryogenic Piezo Stages - Linear positioners
Compact cryogenic Z elevation stage; 16 x 16 x 10.5 mm body; 3 mm coarse travel; 250 g payload; spring-counterbalanced Z mechanics; optional resistive closed-loop encoder around 150 nm resolution.
Datasheet (PDF) ↗CAD Model (STEP) ↗Catalog context
Linear16-z is listed in the Cryogenic Piezo Stages - Linear positioners family. The local catalog record provides these first selection fields: Active axes: Z; Footprint × hight: 16x16x16 mm; Mass: 12 g.
| Active axes | Z |
|---|---|
| Footprint × hight | 16x16x16 mm |
| Mass | 12 g |
| Work environment | 1.4~ 400 K, Max. Magnetic field: 35 Tesla |
| Mainbody | Pure Ti |
| Wires | Phosphor Bronze Twisted Paired Wires, 20cm |
| Pin materials | Polyster (glass fiber filled), BeCu |
| Pins number | Drive -4 pins, Sensor- 3 pins |
| Fine Tune Resolution @2 K* | sub nm |
| Step Size (min) @300 K* | ~10 nm |
| Travel range | 3 mm |
| Max. Velocity @300 K | ~2 mm/s |
| Max. Load | 250 g |
| Dynamic force | 3 N |
| Position encoder | Resistive Sensor |
| Encoder range | 3 mm |
| Sensor resolution | ~150 nm |
| Repeatibility | 1-2 um |
Application context
Move a sample under a fixed optical access port at temperatures down to the millikelvin range.
Bring a tip from millimetres away into tunnelling or contact range before fine scan takes over.
Set working distance after cooldown, once thermal contraction has moved everything.
System integration
Use these checks to connect Linear16-z to the surrounding optical, mechanical and control system. Every value shown is taken from this model's own specification record.
Technical FAQ
Fine Tune Resolution @2 K*: sub nm · Step Size (min) @300 K*: ~10 nm. Separate travel from resolution and both from repeatability. Repeatability is what an automated sequence actually depends on, and it is the figure most often absent from a headline specification.
Position encoder: Resistive Sensor · Encoder range: 3 mm. Pair open-loop mechanics with the specified high-voltage or inertial driver, and closed-loop variants with the controller their capacitive, strain-gauge or encoder feedback requires. Matching connectors do not guarantee electrical compatibility.
Max. Load: 250 g. Check the load rating in the orientation you will use it — a vertical or cantilevered load is a moment, not a mass — and match the base to an M6 pattern on a 25 mm grid or a 1/4"-20 pattern on a 1 inch grid.
Specifying this part
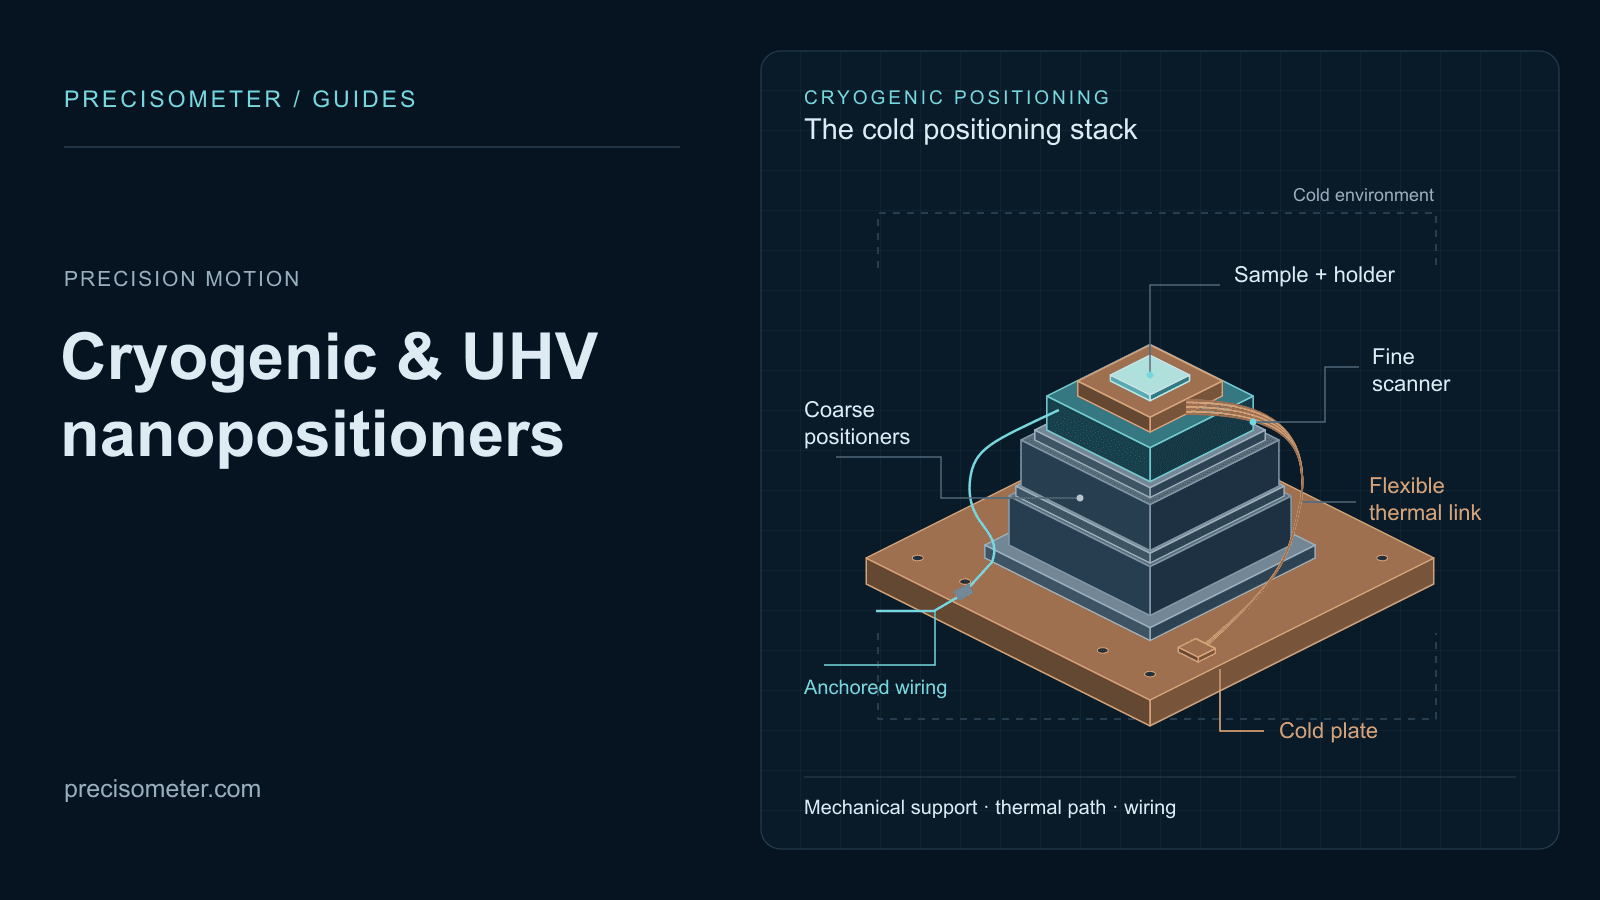
Coarse travel on these stages is mechanical rather than piezo expansion, so the full 3–20 mm stroke is still available at base temperature. That is the reason a coarse stage is normally stacked under a fine scanner instead of using one actuator for both.
Resistive encoders read to roughly 150 nm — enough to return to a feature between runs, not to hold one against drift for hours. For that case the capacitive Ultra scanners close the loop at 0.5 nm.
Stick-slip inertial drives dissipate energy per step and draw no holding current once stopped, so the steady-state load on the mixing chamber is the wiring loom rather than the motor. Anchor the loom at each temperature stage and thermalise the moving body with an FTC copper braid.
Titanium bodies (BeCu on the .ULT variants) and BeCu fasteners throughout, rated for operation to 35 T and down to 30 mK with the .ULT option, at 2 × 10⁻¹¹ mbar with .UHV. A single steel screw substituted at installation is enough to compromise a high-field assembly.
Full series comparison, controller pairing and mounting hardware on the cryogenic piezo stages overview, or work through the selection with the configurator.
Model selection
Compare Linear16-z with the closest available models in the Cryogenic Piezo Stages - Linear positioners family.
| Selection parameter | Linear16-z (current) | Linear16-x | Linear25-x |
|---|---|---|---|
| Travel / adjustment | 3 mm | 3 mm | 6 mm |
| Resolution / sensitivity | sub nm | sub nm | sub nm |
Linear16-x
Compact cryogenic X linear stage; 16 x 16 x 10.5 mm body; 3 mm coarse travel; 50 g payload; pure titanium construction; optional resistive closed-loop encoder around 150 nm resolution.
Linear25-x
General-purpose cryogenic X linear stage; 25 x 25 x 9.5 mm body; 6 mm coarse travel; 500 g payload; optional resistive closed-loop encoder around 150 nm resolution.
Linear25-z
General-purpose cryogenic Z elevation stage; 25 x 25 x 9.5 mm body; 6 mm coarse travel; 300 g payload; optional resistive closed-loop encoder around 150 nm resolution.
Linear25-z.LR
Long-range cryogenic Z elevation stage in the Linear25 profile; 25 mm class body; extended Z travel configuration; compatible with resistive closed-loop feedback.
Before you specify
Engineering context for choosing this class of component, with the tradeoffs worked through on real specifications.
 Precision motion
Translate temperature, pressure, travel, payload, feedback, and motion requirements into a defensible cryogenic-stage shortlist.
Open guide Precision motion
The practical companion to the selection guide: a requirements worksheet, coarse and fine stage pairing, mechanical stack order, thermal anchoring, the wiring chain to the controller, vacuum and field checks, a commissioning sequence, and three worked configurations.
Open guide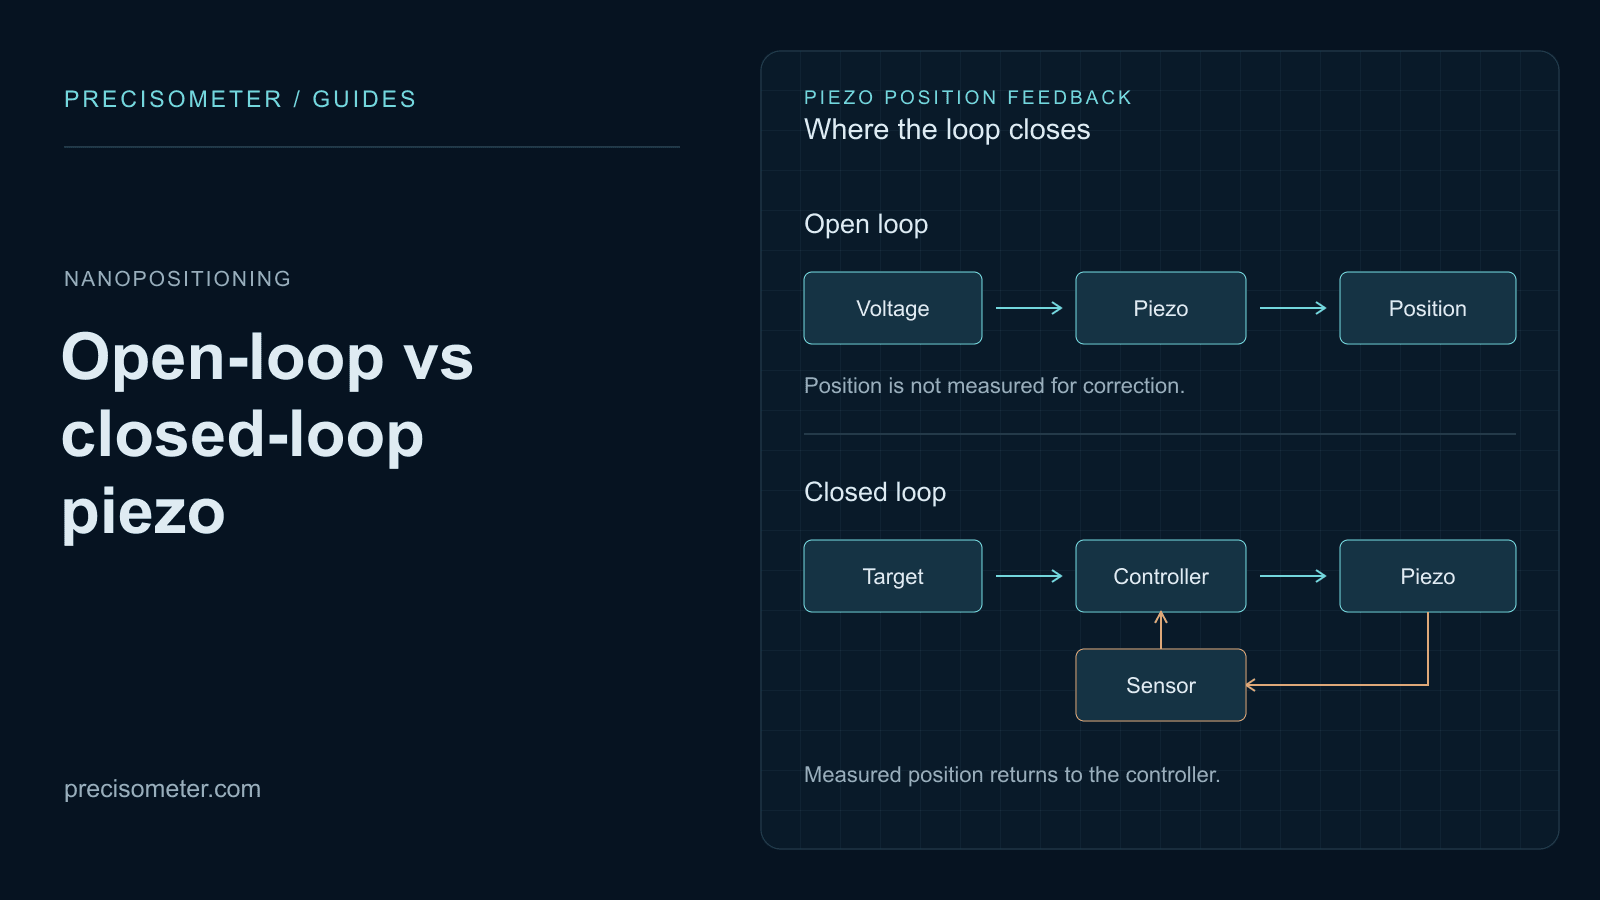 Nanopositioning
Why an open-loop piezo is wrong by 15 % of its travel, how creep grows with the logarithm of hold time, what strain-gauge and capacitive feedback actually fix — and the bandwidth and sensor noise a servo costs you in return.
Open guide