Continuous industrial duty
Repeated indexing on production and inspection rigs that run unattended for long shifts.
Opto-Mechanics · Ambient Piezo Stages - Indus linear stages
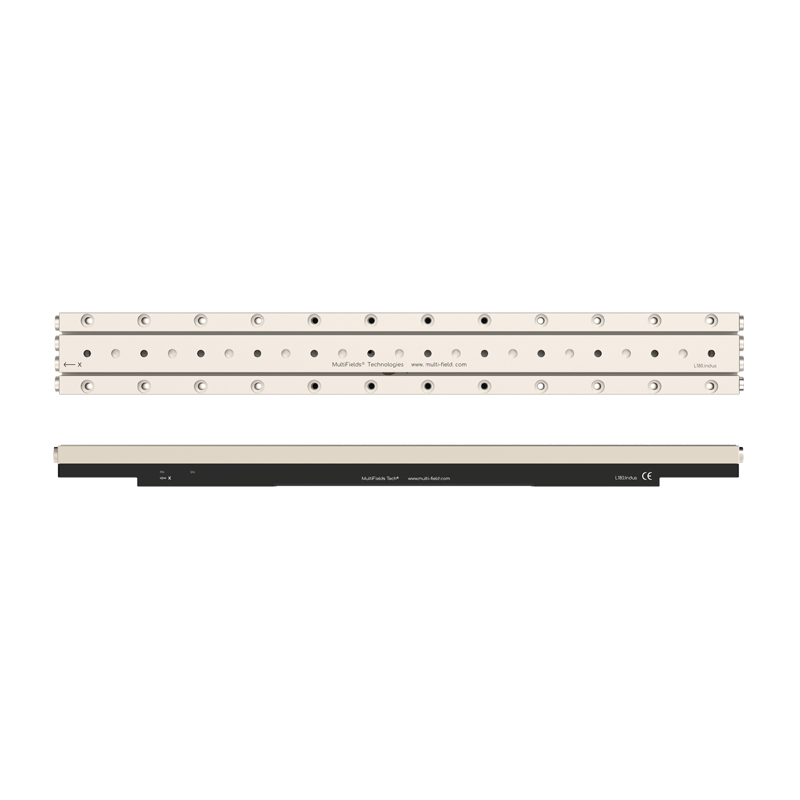
Indus long-travel piezo linear stage; 250 x 36 x 16.5 mm footprint; 150 mm travel; 840 g mass; 3 kg payload; 2 nm encoder class with self-locking stick-slip drive; .HV, .UHV, and .NM variants available.
Datasheet (PDF) ↗CAD Model (STEP) ↗Catalog context
L150.Indus is listed in the Ambient Piezo Stages - Indus linear stages family. The local catalog record provides these first selection fields: Active axes: X; Mass: 840 g; Travel range: 150 mm.
| Active axes | X |
|---|---|
| Mass | 840 g |
| Travel range | 150 mm |
| Max Driving Frequency | 20 kHz |
| Max. Velocity | 10 mm/s |
| Minimum Incremental Motion(Close-loop) | 10 nm |
| Max. Push Force | 2 N |
| Holding Force | 3 N |
| Max. Payload (horizontal mounting) | 1 kg |
| Sensor Type | Optical Sensor |
| Sensor Resolution | 2 nm |
| Controller | MC-Newton.S series |
Application context
Repeated indexing on production and inspection rigs that run unattended for long shifts.
Move parts between fixed measurement stations with repeatability holding across thousands of cycles.
Serve as the motion element inside a larger instrument rather than on an open optical table.
System integration
Use these checks to connect L150.Indus to the surrounding optical, mechanical and control system. Every value shown is taken from this model's own specification record.
Technical FAQ
Travel range: 150 mm · Sensor Resolution: 2 nm. Separate travel from resolution and both from repeatability. Repeatability is what an automated sequence actually depends on, and it is the figure most often absent from a headline specification.
Controller: MC-Newton.S series. Pair open-loop mechanics with the specified high-voltage or inertial driver, and closed-loop variants with the controller their capacitive, strain-gauge or encoder feedback requires. Matching connectors do not guarantee electrical compatibility.
Max. Payload (horizontal mounting): 1 kg. Check the load rating in the orientation you will use it — a vertical or cantilevered load is a moment, not a mass — and match the base to an M6 pattern on a 25 mm grid or a 1/4"-20 pattern on a 1 inch grid.
Specifying this part
The Indus series runs from 30 mm to 200 mm of travel with an industrial mounting interface. Chosen for displacement and duty cycle in a machine, not for the finest resolution in the catalogue.
Most of the range is orderable as .HV (high vacuum), .UHV (ultra-high vacuum) or .NM (non-magnetic). The suffix changes materials, cabling and bake compatibility rather than the mechanics, so specify it against the chamber the stage will live in.
Full series comparison, controller pairing and mounting hardware on the ambient piezo stages overview, or work through the selection with the configurator.
Model selection
Compare L150.Indus with the closest available models in the Ambient Piezo Stages - Indus linear stages family.
| Selection parameter | L150.Indus (current) | L100.Indus | LS200.Indus |
|---|---|---|---|
| Travel / adjustment | 150 mm | 100 mm | 200 mm |
| Resolution / sensitivity | 2 nm | 2 nm | 2 nm |
| Mounting interface | 1 kg | 1 kg | 2 kg |
L030.Indus
Indus long-travel piezo linear stage; 60 x 24 x 14 mm footprint; 30 mm travel; 110 g mass; 1 kg payload; 2 nm encoder class with self-locking stick-slip drive; .HV, .UHV, and .NM variants available.
L060.Indus
Indus long-travel piezo linear stage; 105 x 24 x 14 mm footprint; 60 mm travel; 174 g mass; 1 kg payload; 2 nm encoder class with self-locking stick-slip drive; .HV, .UHV, and .NM variants available.
L100.Indus
Indus long-travel piezo linear stage; 180 x 24 x 14 mm footprint; 100 mm travel; 388 g mass; 2 kg payload; 2 nm encoder class with self-locking stick-slip drive; .HV, .UHV, and .NM variants available.
LS200.Indus
Indus long-travel piezo linear stage; 80 x 295 x 20 mm footprint; 200 mm travel; 1050 g mass; 2 kg payload; 2 nm encoder class with self-locking stick-slip drive; .HV, .UHV, and .NM variants available.
Before you specify
Engineering context for choosing this class of component, with the tradeoffs worked through on real specifications.
 Nanopositioning
Decide what to move — sample, objective or both — then turn field of view, stack depth, settling and synchronisation into stage specifications. Comparison tables, an acquisition-time calculator, three configurations and a purchasing checklist on documented objective scanners, clear-aperture XYZ stages and controllers.
Open guide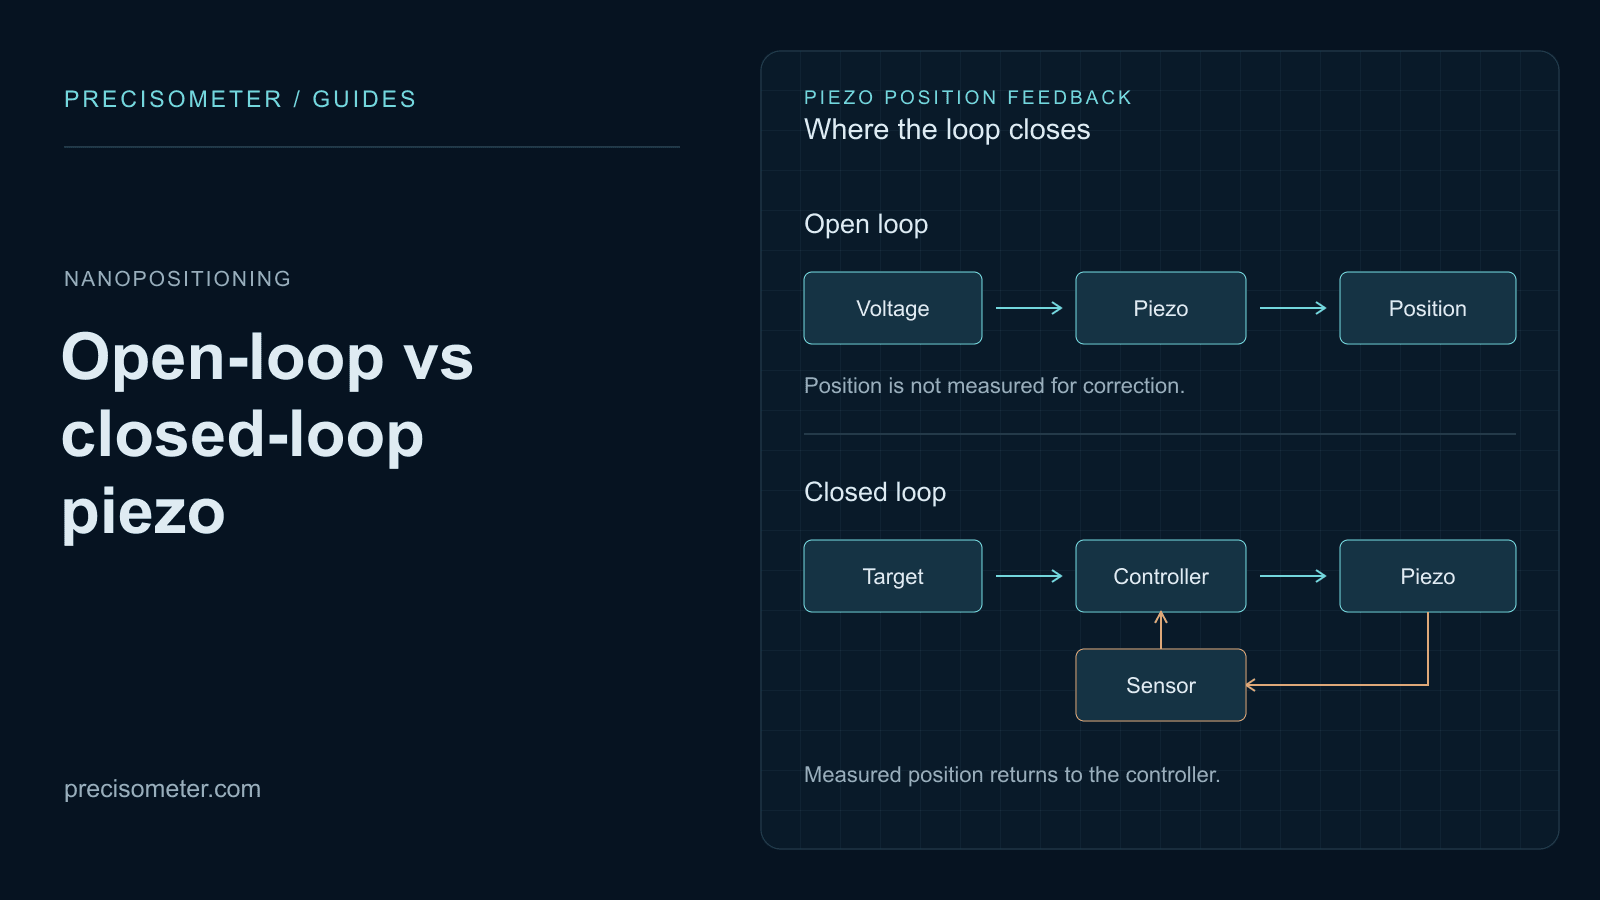 Nanopositioning
Why an open-loop piezo is wrong by 15 % of its travel, how creep grows with the logarithm of hold time, what strain-gauge and capacitive feedback actually fix — and the bandwidth and sensor noise a servo costs you in return.
Open guide Nanopositioning
Piezo ceramic strains by one part in a thousand, so a 20 mm stack gives 20 µm. Every stage architecture is a different way around that limit — and each one wins a different experiment.
Open guide