Driving multi-axis stacks
Coordinate several piezo axes from one chassis so motion stays synchronised.
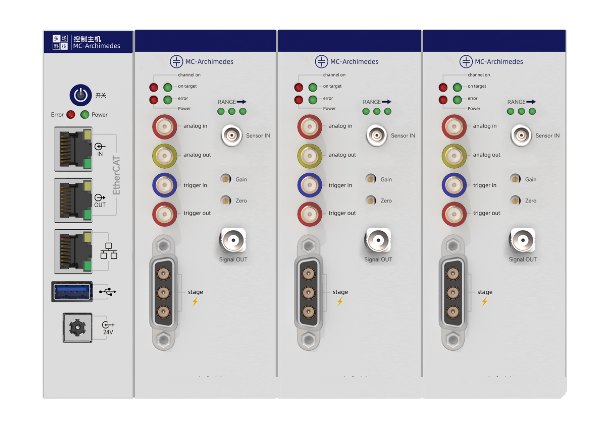
Representative image of the product family.
Opto-Mechanics · Ambient Piezo Stages - Controllers
Digital FPGA-based multi-channel piezo scanner controller providing up to 8 independent drive channels with -20 V to +150 V output and 24 W per channel. Designed for room-temperature flexure scanning stages and fast steering mirrors (S, SD, SH, Carrier.S/SL/OB, and Mirrors series), supporting both capacitive (.C) and strain-gauge (.S) sensor feedback sampled at 20 kHz or 50 kHz. Features D-Sub 3W3 connectors, USB and Ethernet host interfaces, 0–10 V analog input, and SMA TTL synchronization triggers.
Datasheet (PDF) ↗Catalog context
MC-Archimedes.N is listed in the Ambient Piezo Stages - Controllers family. The local catalog record provides these first selection fields: Controlled channels: Up to 8 channels (modular N ≤ 8); Controller architecture: High-speed FPGA digital processing; Target positioners: Piezo flexure scanners (S, SD, SH, Carrier) & fast steering mirrors.
| Controlled channels | Up to 8 channels (modular N ≤ 8) |
|---|---|
| Controller architecture | High-speed FPGA digital processing |
| Target positioners | Piezo flexure scanners (S, SD, SH, Carrier) & fast steering mirrors |
| Control mode | Closed-loop and open-loop |
| Sensor feedback options | Capacitive sensor (.C) or strain-gauge sensor (.S) |
| Sensor sampling rate | 20 kHz / 50 kHz real-time sampling |
| Output voltage range | -20 V ~ +150 V |
| Max output power | 24 W per channel |
| Host communication interface | USB, Ethernet (RJ45) |
| Analog input | 0 ~ 10 V (single-ended) |
| Hardware trigger | SMA connector, TTL (3.3 V) |
| Stage connectors | D-Sub 3W3 |
| Power supply | 24 V DC & (24 × N) W |
| Power input connector | IEC inlet |
| Dimensions (W × D × H) | 230 × 120 × (30 × (N + 1)) mm |
| Control software | PC GUI and secondary development SDK |
Application context
Coordinate several piezo axes from one chassis so motion stays synchronised.
Read capacitive or resistive sensors and hold commanded position against drift and load.
Integrate motion into an experiment through the SDK rather than driving it from the front panel.
System integration
Use these checks to connect MC-Archimedes.N to the surrounding optical, mechanical and control system. Every value shown is taken from this model's own specification record.
Technical FAQ
Controller architecture: High-speed FPGA digital processing · Sensor feedback options: Capacitive sensor (.C) or strain-gauge sensor (.S). Pair open-loop mechanics with the specified high-voltage or inertial driver, and closed-loop variants with the controller their capacitive, strain-gauge or encoder feedback requires. Matching connectors do not guarantee electrical compatibility.
Specifying this part
MC-Newton drives stick-slip motor stages in single-channel and modular multi-channel forms; MC-Archimedes drives capacitive-sensor scanners; MC-Free6D runs the parallel kinematic platforms. A scanner controller will not drive a motor stage, or the reverse.
Most of the range is orderable as .HV (high vacuum), .UHV (ultra-high vacuum) or .NM (non-magnetic). The suffix changes materials, cabling and bake compatibility rather than the mechanics, so specify it against the chamber the stage will live in.
Full series comparison, controller pairing and mounting hardware on the ambient piezo stages overview, or work through the selection with the configurator.
MC-Newton.S
Single-channel precision piezo motor controller designed for room-temperature inertia stick-slip actuators and stages (including Lab, Indus, Mini, and Carrier.L series). Provides 0–75 V high-bandwidth output with up to 30 W driving power, supporting both open-loop stepping and closed-loop positioning with nanometer-scale incremental optical encoders. Equipped with USB, Ethernet, and RS-485 host interfaces, 0–10 V analog input, and SMA TTL hardware triggers for synchronized experimental workflows.
MC-Newton.E4
Four-channel dedicated piezo screw actuator controller engineered for AutoScrew motorized optic mounts and mirror adjusters. Features 4 independently controllable output channels delivering 120 V pulses at up to 2 kHz driving frequency to achieve smooth, sub-microradian optical alignment with high holding stability. Includes front-panel manual adjustment buttons, USB interface, and standard SMB motor connectors.
MC-Newton.MSx
Modular multi-channel piezo motor controller supporting 1 to 10 independent drive channels for multi-axis room-temperature stick-slip stages. Each channel delivers 0–75 V output with up to 30 W drive power (100 W total system power) and supports closed-loop operation with incremental optical encoders. Features front-panel manual navigation buttons, USB, Ethernet, RS-485, optional EtherCAT connectivity, 0–10 V analog inputs, and SMA TTL hardware trigger I/O.
MC-Free6D
Six-channel synchronized motion controller engineered specifically for FreeXD and Free6D 6-DOF parallel-kinematic positioning platforms. Incorporates integrated real-time coordinate transformations, virtual-pivot rotation algorithms, and closed-loop trajectory distribution for optical encoders across all 6 driving struts. Features 24 V DC power, 20 kHz driving frequency, 100 W peak power, USB Type-C, Ethernet, optional EtherCAT, 6 DB15 connectors, and comprehensive 3D simulation software.
Before you specify
Engineering context for choosing this class of component, with the tradeoffs worked through on real specifications.
 Nanopositioning
Decide what to move — sample, objective or both — then turn field of view, stack depth, settling and synchronisation into stage specifications. Comparison tables, an acquisition-time calculator, three configurations and a purchasing checklist on documented objective scanners, clear-aperture XYZ stages and controllers.
Open guide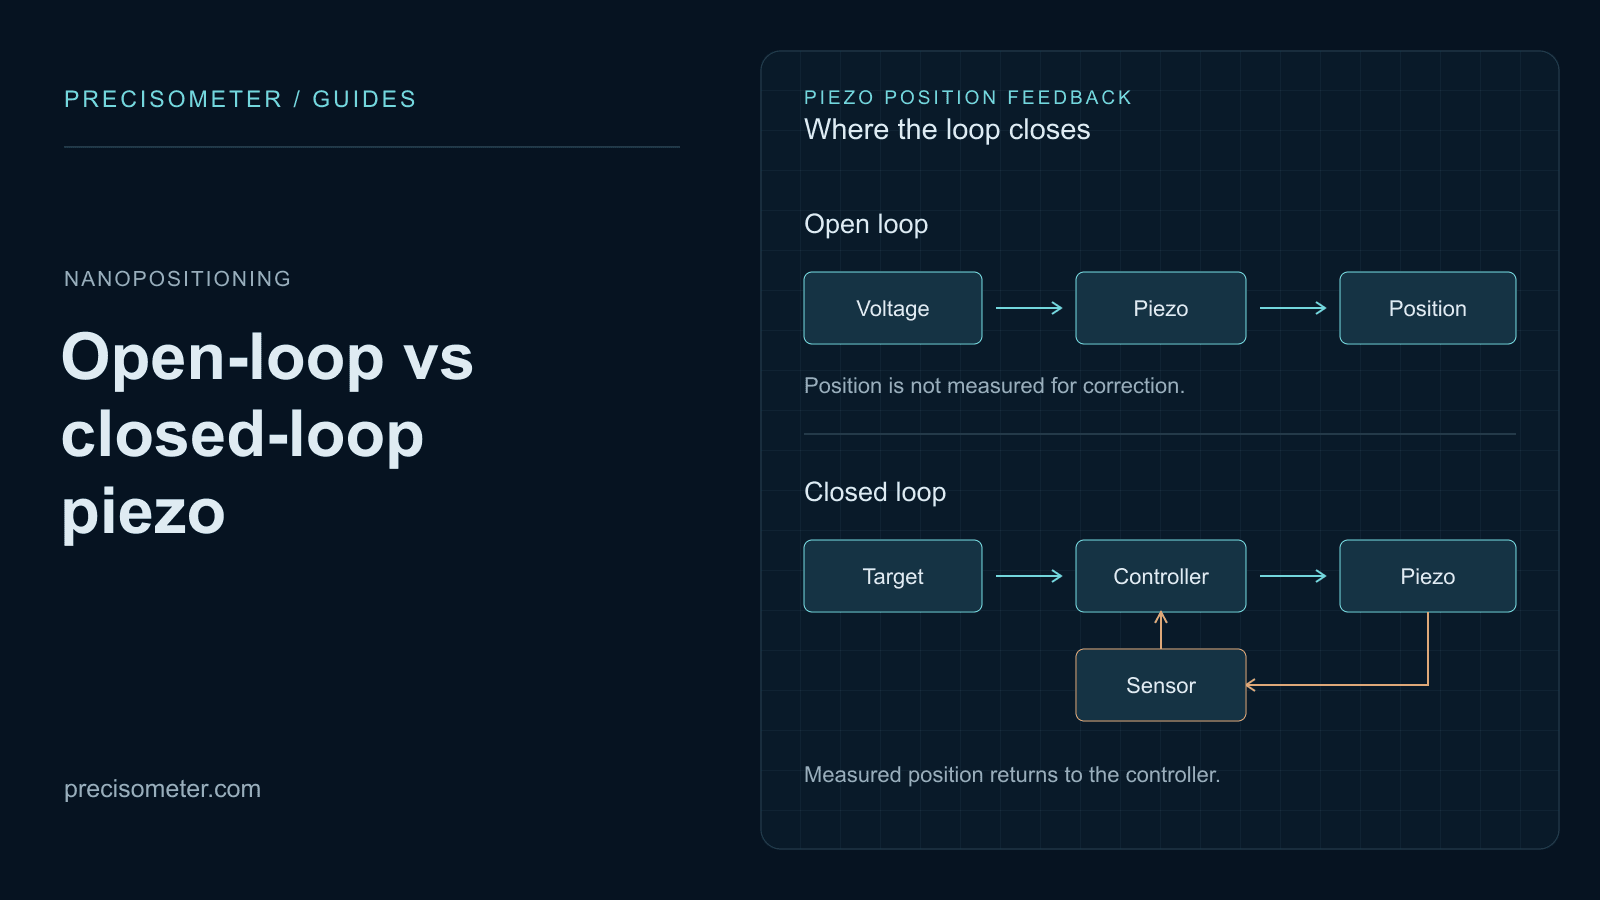 Nanopositioning
Why an open-loop piezo is wrong by 15 % of its travel, how creep grows with the logarithm of hold time, what strain-gauge and capacitive feedback actually fix — and the bandwidth and sensor noise a servo costs you in return.
Open guide Nanopositioning
Piezo ceramic strains by one part in a thousand, so a 20 mm stack gives 20 µm. Every stage architecture is a different way around that limit — and each one wins a different experiment.
Open guide