Opto-Mechanics · Ambient Piezo Stages - Controllers
MC-Newton.E4
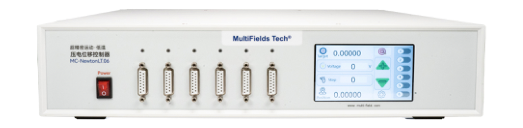
Four-channel dedicated piezo screw actuator controller engineered for AutoScrew motorized optic mounts and mirror adjusters. Features 4 independently controllable output channels delivering 120 V pulses at up to 2 kHz driving frequency to achieve smooth, sub-microradian optical alignment with high holding stability. Includes front-panel manual adjustment buttons, USB interface, and standard SMB motor connectors.
Datasheet (PDF) ↗Cataloguscontext
De plaats van MC-Newton.E4 in het assortiment
MC-Newton.E4 staat vermeld binnen de familie Ambient Piezo Stages - Controllers. Het lokale catalogusrecord bevat als eerste selectievelden: Controlled channels: 4 channels (independent drive); Application / target actuator: AutoScrew piezo screw actuator sets for mirror mounts; Control mode: Open-loop stepping.
Specifications
| Controlled channels | 4 channels (independent drive) |
|---|---|
| Application / target actuator | AutoScrew piezo screw actuator sets for mirror mounts |
| Control mode | Open-loop stepping |
| Driving voltage | 120 V |
| Driving frequency | 2000 Hz |
| Host communication interface | USB |
| Motor connectors | 4 × SMB connectors |
| Power supply | 12 V DC |
| Manual control | Front-panel channel buttons |
| Control software | PC GUI and ASCII command code protocol |
Toepassingen
Aansturen van meerassige stapels
Coördineer meerdere piëzo-assen vanuit één kast, zodat de beweging synchroon blijft.
Closed-loop servoregeling
Lees capacitieve of resistieve sensoren en houd de commandopositie vast tegen drift en belasting.
Scriptbare en externe bediening
Integreer beweging in een experiment via de SDK in plaats van via het frontpaneel.
Specifying this part
What this model has to survive, and what it needs around it
Match the controller to the drive type
MC-Newton drives stick-slip motor stages in single-channel and modular multi-channel forms; MC-Archimedes drives capacitive-sensor scanners; MC-Free6D runs the parallel kinematic platforms. A scanner controller will not drive a motor stage, or the reverse.
Vacuum and non-magnetic versions
Most of the range is orderable as .HV (high vacuum), .UHV (ultra-high vacuum) or .NM (non-magnetic). The suffix changes materials, cabling and bake compatibility rather than the mechanics, so specify it against the chamber the stage will live in.
Full series comparison, controller pairing and mounting hardware on the ambient piezo stages overview, or work through the selection with the configurator.
Related products
MC-Newton.S
Single-channel precision piezo motor controller designed for room-temperature inertia stick-slip actuators and stages (including Lab, Indus, Mini, and Carrier.L series). Provides 0–75 V high-bandwidth output with up to 30 W driving power, supporting both open-loop stepping and closed-loop positioning with nanometer-scale incremental optical encoders. Equipped with USB, Ethernet, and RS-485 host interfaces, 0–10 V analog input, and SMA TTL hardware triggers for synchronized experimental workflows.
MC-Newton.MSx
Modular multi-channel piezo motor controller supporting 1 to 10 independent drive channels for multi-axis room-temperature stick-slip stages. Each channel delivers 0–75 V output with up to 30 W drive power (100 W total system power) and supports closed-loop operation with incremental optical encoders. Features front-panel manual navigation buttons, USB, Ethernet, RS-485, optional EtherCAT connectivity, 0–10 V analog inputs, and SMA TTL hardware trigger I/O.
MC-Archimedes.N
Digital FPGA-based multi-channel piezo scanner controller providing up to 8 independent drive channels with -20 V to +150 V output and 24 W per channel. Designed for room-temperature flexure scanning stages and fast steering mirrors (S, SD, SH, Carrier.S/SL/OB, and Mirrors series), supporting both capacitive (.C) and strain-gauge (.S) sensor feedback sampled at 20 kHz or 50 kHz. Features D-Sub 3W3 connectors, USB and Ethernet host interfaces, 0–10 V analog input, and SMA TTL synchronization triggers.
MC-Free6D
Six-channel synchronized motion controller engineered specifically for FreeXD and Free6D 6-DOF parallel-kinematic positioning platforms. Incorporates integrated real-time coordinate transformations, virtual-pivot rotation algorithms, and closed-loop trajectory distribution for optical encoders across all 6 driving struts. Features 24 V DC power, 20 kHz driving frequency, 100 W peak power, USB Type-C, Ethernet, optional EtherCAT, 6 DB15 connectors, and comprehensive 3D simulation software.