Zolix · Motorized Stages
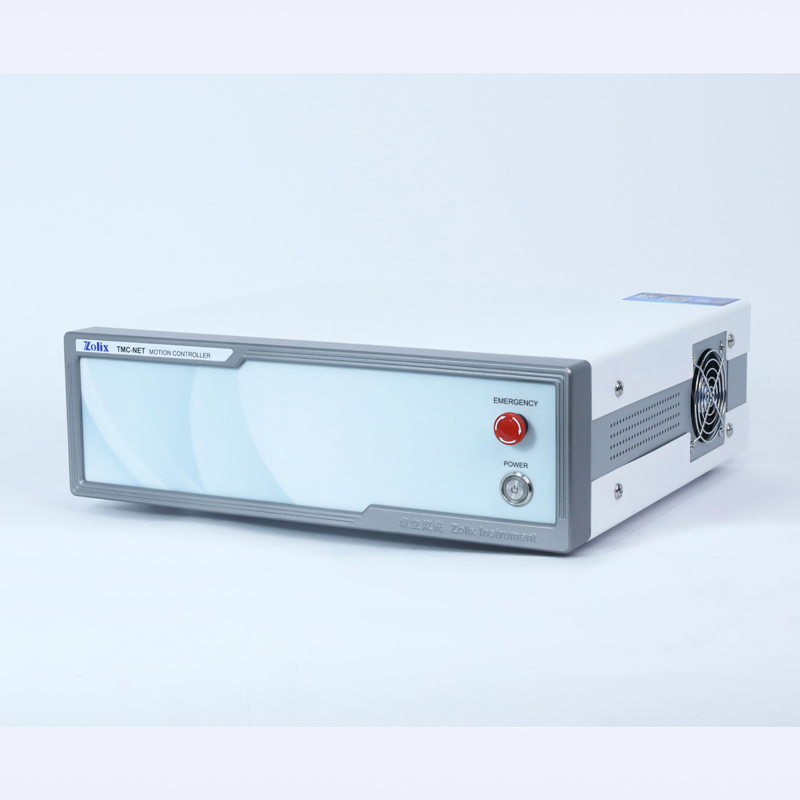
TMC-NET-HXP HXP High Precision Hexapod
6-axis TMC-NET motion controller and control software dedicated for HXP series high-precision hexapods. Provides Ethernet host communication, 64-bit multi-axis coordinate transformations, and kinematic coordinated trajectory control for parallel robotics.
- Rated voltage (V)
- AC 220
- Rated current
- 1.5 A
- Rated power (W)
- 350
- Operating temperature (°C)
- 0 ~ +55
Specifications
| Rated voltage (V) | AC 220 |
|---|---|
| Rated current (A) | 1.5 |
| Rated power (W) | 350 |
| Operating temperature (°C) | 0 ~ +55 |
| Type of each axis | EtherCAT/RTEX/6 differential pulse axes (the output port can be equipped with 6 single-ended pulse axes) |
| Internal I/O port number | 24 inputs and 12 outputs (with overcurrent protection and built-in expansion) |
| Internal ADDA number | 2-channel AD, 2-channel DA (0-10V, built-in expansion) |
| Maximum expansion AD/DA | 256 AD, 128 DA |
| Number of pulses | 64 |
| Encoder Bits | 64 |
| Speed acceleration digits | 64 |
| Pulse maximum rate | 10Mhz |
| Number of motion buffers per axis | 4096 |
| Array Space | 640000 |
| Program Space | 8000Kbyte |
| Flash Space | 256MByte |
| Communication Interface | External: Ethernet Built-in expansion: RS232, RS485, Ethernet, USB, CAN, RTEX, EtherCAT |